Wolfram Function Repository
Instant-use add-on functions for the Wolfram Language
Function Repository Resource:
Convert a unit quaternion to an equivalent rotation matrix
ResourceFunction["QuaternionToRotationMatrix"][w] converts the unit quaternion w into an equivalent 3×3 rotation matrix. |
Define a quaternion:
| In[1]:= |

|
| Out[1]= |
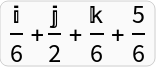
|
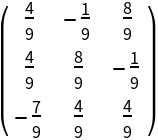
Generate a rotation matrix from a unit quaternion:
| In[2]:= |

|
| Out[2]= |
|
Verify that the result is a rotation matrix:
| In[3]:= |
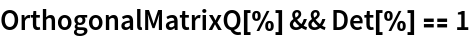
|
| Out[3]= |

|
An exact quaternion:
| In[4]:= |

|
| Out[4]= |
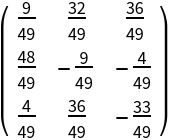
|
An approximate MachinePrecision quaternion:
| In[5]:= |

|
| Out[5]= |
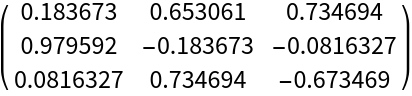
|
An approximate arbitrary precision quaternion:
| In[6]:= |

|
| Out[6]= |

|
QuaternionToRotationMatrix threads over lists:
| In[7]:= |
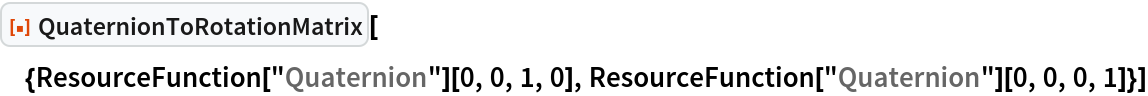
|
| Out[7]= |
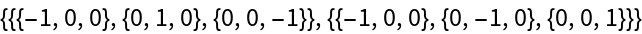
|
Create a unit quaternion:
| In[8]:= |
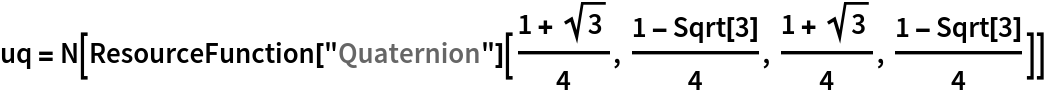
|
| Out[8]= |

|
Also define a vector to be rotated:
| In[9]:= |

|
| Out[9]= |
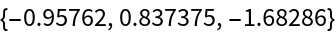
|
Transform the vector using the quaternion representation of a rotation:
| In[10]:= |
![Rest[Apply[
List, (uq ** Apply[ResourceFunction["Quaternion"], Prepend[vec, 0]]) ** Power[uq, -1]]]](https://www.wolframcloud.com/obj/resourcesystem/images/754/75487094-1ad3-490d-9d43-70ef1de35fd7/1-0-0/42dacf4bc3647514.png)
|
| Out[10]= |
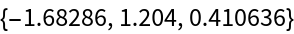
|
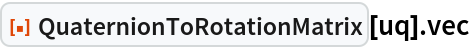
Transform the vector using the rotation matrix representation to get the same result:
| In[11]:= |
|
| Out[11]= |
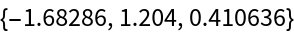
|
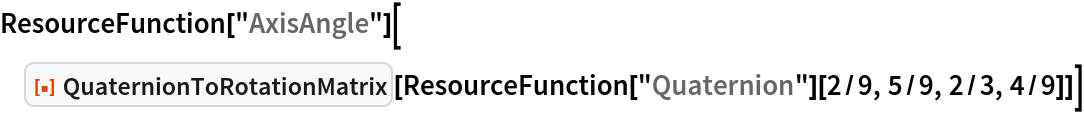
Get the axis-angle representation of a quaternion:
| In[12]:= |
|
| Out[12]= |
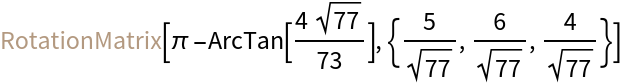
|
Recover the original quaternion:
| In[13]:= |
![Apply[ResourceFunction["Quaternion"], Prepend[Sin[First[%]/2] Last[%], Cos[First[%]/2]]] // FullSimplify](https://www.wolframcloud.com/obj/resourcesystem/images/754/75487094-1ad3-490d-9d43-70ef1de35fd7/1-0-0/5c08b34247f9f9d7.png)
|
| Out[13]= |
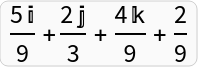
|
This work is licensed under a Creative Commons Attribution 4.0 International License